Mining Collision Avoidance Built Around Multiple Layers of Awareness
Mining environments create constantly changing interactions between heavy equipment, light vehicles, support equipment and people.
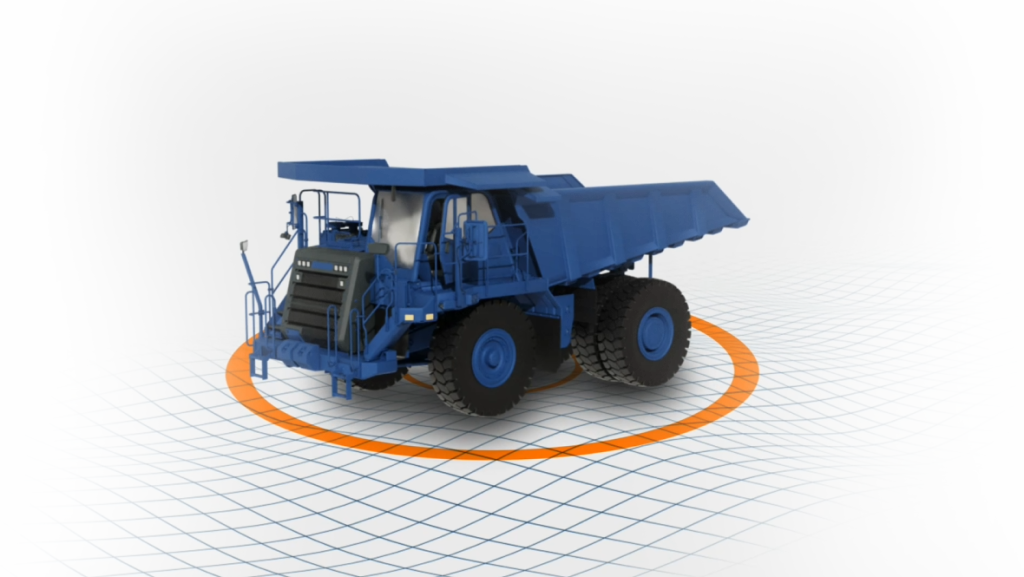
PerceptN is RaptorTech’s mining collision avoidance and proximity-awareness technology, combining multiple sensing and positioning layers to give operators richer context around developing vehicle interactions.
Vehicle Interaction Is More Complex Than Proximity Alone
The challenge is not simply knowing that another object is nearby. Operators need useful awareness of the interactions developing around the machine, while supervisors and safety teams need enough context to understand recurring interaction risk.
PerceptN is designed around that broader vehicle-interaction problem.
A Layered Approach to Mining Collision Awareness
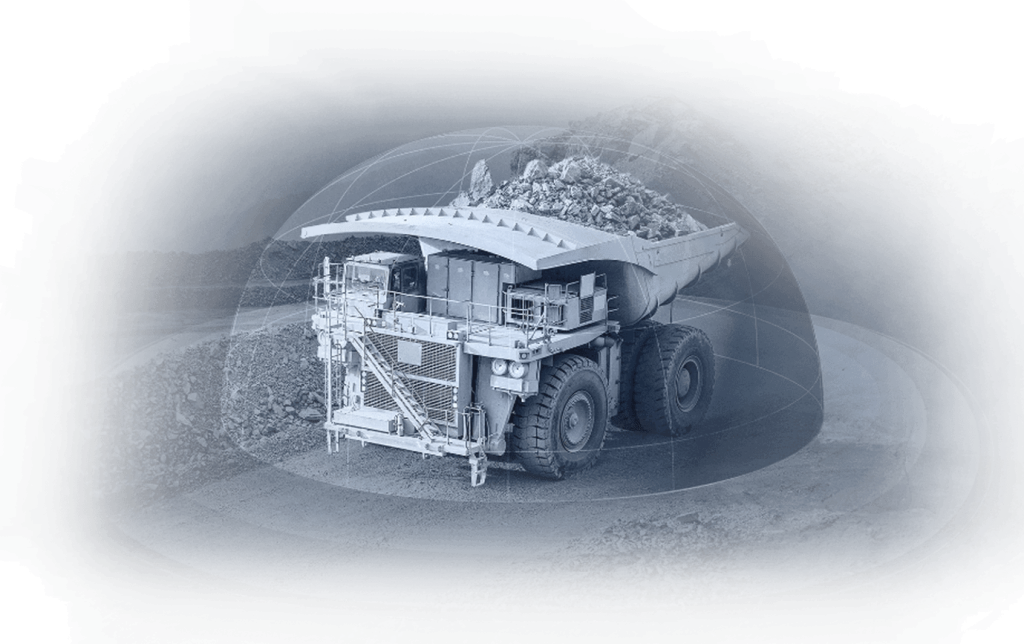
PerceptN combines stereo machine vision, 4D radar, high-precision GNSS and peer-to-peer communications to provide layered collision awareness. The hardware supports recognition and depth perception, radar provides range and relative movement, GNSS provides accurate positioning, and peer-to-peer communications allow equipped assets to exchange movement information directly.
Stereo Machine Vision
Supports recognition and depth perception.
4D Radar
Provides range and relative-movement information.
High-Precision GNSS
Provides accurate positioning.
Peer-to-Peer Communications
Allows equipped assets to exchange movement information directly.
Warnings Designed Around Relevant Interactions
PerceptN uses equipment position, movement, direction and configurable risk zones to determine when warnings are required, helping reduce unnecessary alarm fatigue while preserving relevant operator alerts.
Configurable risk zones allow warnings to be aligned with the operating environment.
Useful Warnings Matter More Than More Warnings
PerceptN uses configurable risk zones and movement information to focus operator warnings on relevant interactions.
This approach is designed to reduce alarm fatigue while preserving relevant operator alerts.
Support Visibility Beyond the Operator
PerceptN records interaction events and supports historical playback, heatmaps and event reporting so operations and safety teams can identify recurring vehicle-interaction patterns.
RaptorTech is OEM-agnostic and designed for mixed-fleet mining environments, with RaptorTech capabilities able to coexist and integrate with existing mine-site technology where compatibility is supported.
PerceptN Within the RaptorOS Environment
PerceptN provides collision avoidance and proximity-awareness capability within RaptorOS, alongside FleetM fleet management, PerceptAuto braking intervention and PrecisN machine guidance.
Practical Deployment Into Existing Mining Operations
A PerceptN deployment can include fleet and site assessment, vehicle suitability review, hardware installation, calibration, site-specific interaction configuration, operational validation, training and ongoing support.
Evaluate PerceptN in the Context of Your Operation
See how PerceptN identifies and communicates vehicle interactions across realistic mining scenarios.
PerceptN is RaptorTech’s mining collision avoidance and proximity-awareness technology, designed to support operator awareness of mobile-equipment interactions.
PerceptN supports mining interaction scenarios including heavy/light vehicle interactions, blind spots, intersections, reversing and equipment operating in close proximity.
No. Collision-avoidance technology supports mobile-equipment risk management but does not replace operating procedures, critical controls, training or site safety responsibilities.
Discuss Mobile-Equipment Interaction Risk at Your Mine
Talk to RaptorTech about your fleet, operating environment and the vehicle-interaction scenarios you need to manage.